

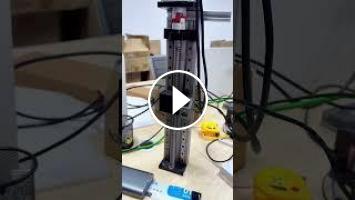
A single-axis linear stage stands on a workbench: a ball screw runs inside an aluminum extrusion frame, a carriage rides on linear rails, and a small control box with a pressure pad sits nearby. A finger presses the pad, and the ball screw responds instantly—moving the carriage up or down in exact proportion to the pressure applied. Press harder, it moves faster. Lighten the touch, it slows. Release, and it stops dead. The motion is fluid, with no overshoot, no lag, no hunting for position. What looks like a simple demo is actually a force-to-position control loop running in real time: the human hand supplies the setpoint, and a PID controller closes the loop on the servo motor driving the ball screw.
※ Key Features & Why It Works:
▪ ※ What This Device Actually Is: A force-sensitive input pad reads how hard the operator pushes, and a PID controller translates that force signal into a velocity or position command for the servo motor. The ball screw converts rotary motion into precise linear travel. The result is a machine that mirrors human intent in real time, without programming waypoints or writing motion profiles.
▪ ※ Why Ball Screw, Not Belt or Rack: Ball screws offer low backlash and high positional repeatability—critical when the machine must start, stop, and reverse on a dime in response to a changing human input. A belt would stretch and bounce; a rack would have tooth engagement lag. The ball screw's rolling contact gives the stiffness and responsiveness the control loop needs.
▪ ※ Where This Gets Used: Force-guided positioning shows up in medical device assembly, where a technician needs to feel resistance while inserting fragile components; in semiconductor handling, where wafer placement demands sub-millimeter accuracy guided by operator touch; in prosthetic and orthotic fitting, where a clinician shapes a limb socket by hand while the machine tracks the pressure profile; and in collaborative robotics, where a human and a machine share control of a single motion axis.
▪ ※ What Problem It Solves: Traditional CNC and robotic systems run pre-programmed paths. They are fast and repeatable, but they cannot react to what the operator feels in the moment. Force-guided control bridges that gap—it keeps the precision and power of a servo-driven ball screw, but hands the decision-making back to the human hand. The machine does not replace the operator; it amplifies the operator's sense of touch.
▪ ※ Why the Demo Looks So Smooth: The PID loop is tuned for responsiveness over raw speed. The proportional term reacts to pressure changes instantly; the integral term eliminates steady-state offset so the carriage does not drift; the derivative term damps oscillation so the motion settles without wobble. When all three terms are balanced, the machine feels like an extension of the finger.
Practical Notes:
If you are building or tuning a similar setup, start with the proportional gain—too high and the stage will oscillate around the setpoint; too low and it will feel sluggish. Add derivative damping only after proportional response is stable; derivative without enough proportional gain just masks the problem. Integral gain should be the last to tune, and kept conservative—integral windup can cause the carriage to overshoot and hunt after a sudden pressure change. Use a ball screw with a low lead (fine pitch) for better force resolution; a coarse lead will make small pressure changes produce large jumps in position. Always include a hardware limit switch at both ends of travel; a runaway servo under force control can damage the stage or the workpiece before software catches it.
- Категория
- AI для YouTube & Shorts
Выполните вход или зарегистрируйтесь для отправки комментария.
Комментариев нет.
Следующее
Auto
-
05:22

Stable Diffusion Hoạt Động Thế Nào? Bí Mật Nằm Ở Đây!
-
03:06
Stable Diffusion Tạo Ảnh Như Thế Nào? Giải Mã 50 Bước Từ Một Seed!
-
00:07
This Robot Learns by Following Your Hand #shorts
-
02:06
AI Hand Craft Video Kaise Banaye | Step-by-Step Full Tutorial 2026 | Viral AI Craft Videos
-
00:11
DIY Automatic Hand Sanitizer Dispenser
-
2 Robot Có Thể Thay Thế Toàn Bộ Nhân Viên Giữ Xe?
-
00:05
Control Servo Motors with Hand Gestures
-
00:19
MÌNH THAY THẾ ĐỐNG DÂY DUPONT BẰNG BREADBOARD #huyaiautomation
-
07:10
Create Viral Mini Rescue AI Videos for FREE | Giant Hand Miniature Videos Tutorial (2026) #ai
-
51:08
NGƯỜI VIỆT GÓP SỨC XÂY DỰNG GROK-3: Hành Trình Từ Huy Chương IMO Đến ĐỈNH CAO AI Thế Giới
-
13:39

Best AI Tools For Research in 2026 (Beats ChatGPT & 0% Detection)
-
00:37

3 AI tools for programmers
-
00:55

The Best AI Tools For Content Creators
-
00:58

7 AI tools you NEED to try!
-
00:12

Best AI Tools For Hacker
-
11:15

10 Best AI Tools You MUST Try in 2025
-
00:28

The most popular AI tools right now... which one is best?
-
00:36

Best Free AI Tools for Research Papers & Essays | Write Smarter!
-
14:34

Google's NEW AI Tools Will BLOW YOUR MIND | Google I/O 2026
-
00:18

Best FREE AI Tools for Designers | Boost Your Creativity #ai #aitools #graphicdesign #designer
 Загрузка...